

Exact implementation and checkpoint
The official KITTI experiment uses geotransformer-kitti.pth.tar from the authors' releases. The repository also has separate 3DMatch and ModelNet experiments; do not interchange their checkpoints or configurations.
How it works
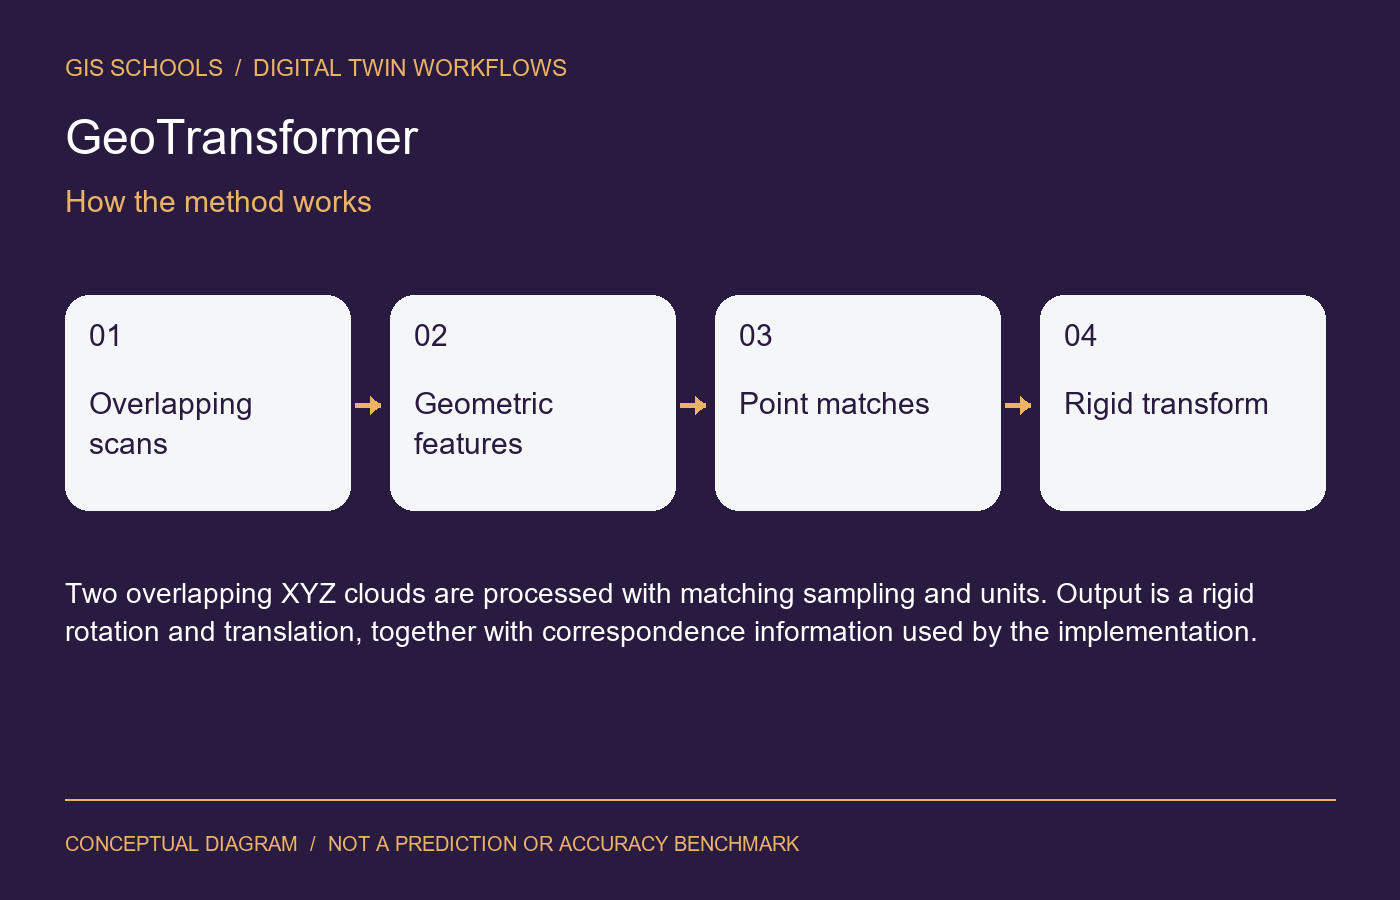
The network uses geometric relationships to find corresponding regions and points. Local-to-global registration estimates a rigid transform from the learned matches.
Inputs and outputs
Two overlapping XYZ clouds are processed with matching sampling and units. Output is a rigid rotation and translation, together with correspondence information used by the implementation.
Training and fine-tuning
Use paired clouds and known relative poses with the selected experiment's data preparation. Fine-tuning needs representative overlap and sensor conditions. Reserve independent routes for evaluation.
GIS and digital twin use
Align repeat survey fragments before comparison or visualization. Keep the original coordinate transforms and control points; convert the final alignment into the digital twin's reference frame.
Validation on your data
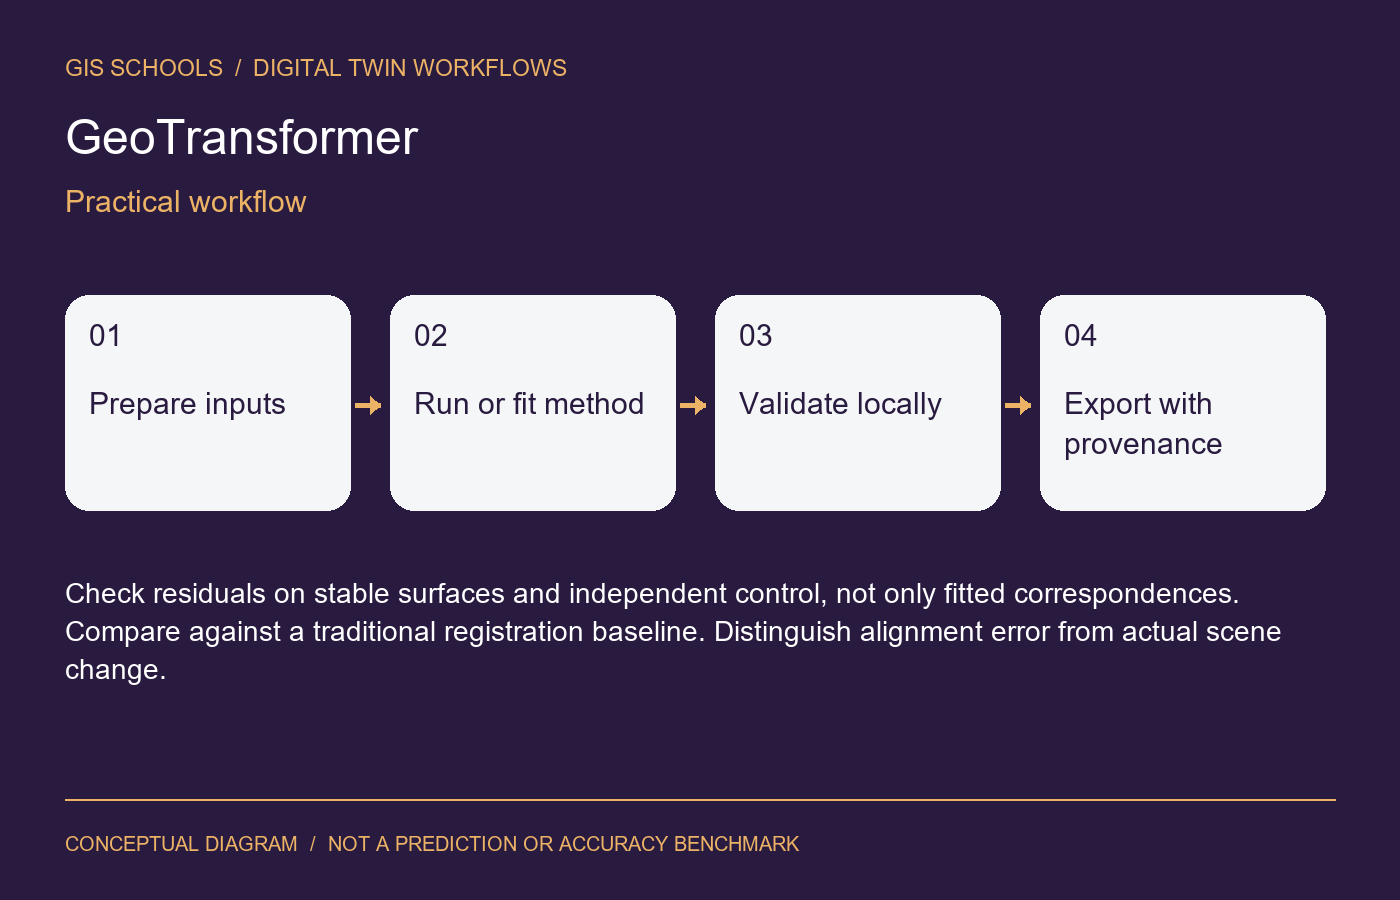
Check residuals on stable surfaces and independent control, not only fitted correspondences. Compare against a traditional registration baseline. Distinguish alignment error from actual scene change.
Limitations
Rigid registration cannot explain real deformation. Repeated structures, moving objects and little overlap can produce plausible but wrong alignment. The documented environment contains older compiled dependencies.
Resources and license
The official repository is MIT licensed and links pretrained releases. Follow the selected dataset's terms and record the exact release/checkpoint hash for reproducible work. This page does not run registration.
Integration and validation status
This is a workflow component, not an installed iTwin plugin or automatic asset update service. Preserve coordinate reference systems, units, acquisition dates and source provenance for spatial outputs; preserve timestamps and sensor units for time-series outputs. Review results before attaching them to an authoritative asset.
GISSchools has not run training, inference or an accuracy benchmark for this entry. Covers and diagrams are conceptual illustrations. Official resources remain external.
Official references
Examples and images
Downloads and resources
The official repository is MIT licensed and links pretrained releases. Follow the selected dataset's terms and record the exact release/checkpoint hash for reproducible work. This page does not run registration.
Comments
No comments yet. Start the discussion.
Leave a reply
Your email address will not be published. Required fields are marked.